N

a

m

a

s

t

e

(

)

;


I

'

m

O

m

k

a

r


K

a

s

h

i

d

I

d

e

s

i

g

n

c

o

d

e

f

o

r

E

m

b

e

d

d

e

d

S

y

s

t

e

m

.

Embedded Software Engineer with 2+ years of experience in firmware development, ARM Cortex-M (STM32), Linux-based embedded systems, and hardware interfacing.

I build reliable real-time embedded applications across robotics, communication protocols (UART, SPI, I2C, CAN), and performance-critical systems.

</AboutMe>

Hi, I am Omkar Kashid, an Embedded Software Engineer focused on firmware and microcontroller-based systems that solve real-world hardware problems.


I work with Embedded C/C++, ARM Cortex-M (STM32), ESP32, Linux platforms, and low-level interfaces such as UART, SPI, I2C, and CAN.


My current focus is robotics and safety-critical embedded applications, where I build reliable software, integrate sensors and peripherals, and optimize systems for stability.

Omkar Kashid profile

</ExperienceHighlights>

Inditech Electro System (Oct 2025 - Present): Leading Fire and Safety Robotics R&D, building real-time embedded software in C++, OpenCV-based vision pipelines, and OpenGL monitoring tools.


Omegasoft Technologies (Jan 2025 - Sep 2025): Developed firmware for STM32 and ESP32, implemented UART/SPI/I2C/CAN interfaces, and optimized Linux-based embedded systems for reliability.


Ingenious Engineering (Jan 2023 - Dec 2023): Built embedded C applications, integrated sensors and industrial I/O, and validated firmware for IoT-enabled systems.

</Skills>

Core Skills and Tools

Core Embedded: Embedded C, C++, ARM Cortex-M, Bare-Metal Programming | Protocols: UART, SPI, I2C, CAN | Platforms: STM32, ESP32, Linux, Raspberry Pi | Tools: Git, GitHub, OpenCV, OpenGL.

  • Embedded C
  • C
  • C++
  • Arm Cortex-M
  • Linux
  • Raspberry Pi
  • Ubuntu
  • Python
  • GITHUB
  • GIT
  • HTML
  • CSS
  • SQL
  • Windows

</Projects>

Fire and Safety Robotics Vision System (R&D)

Built a real-time robotics vision and monitoring pipeline for safety-critical use cases using C++, OpenCV, and OpenGL. Implemented ROI-based motion detection, emergency trigger logic, and live rendering workflows for debugging and diagnostics.

Fire and Safety Robotics project preview
STM32-BareMetalOS-Crafting-from-Scratch

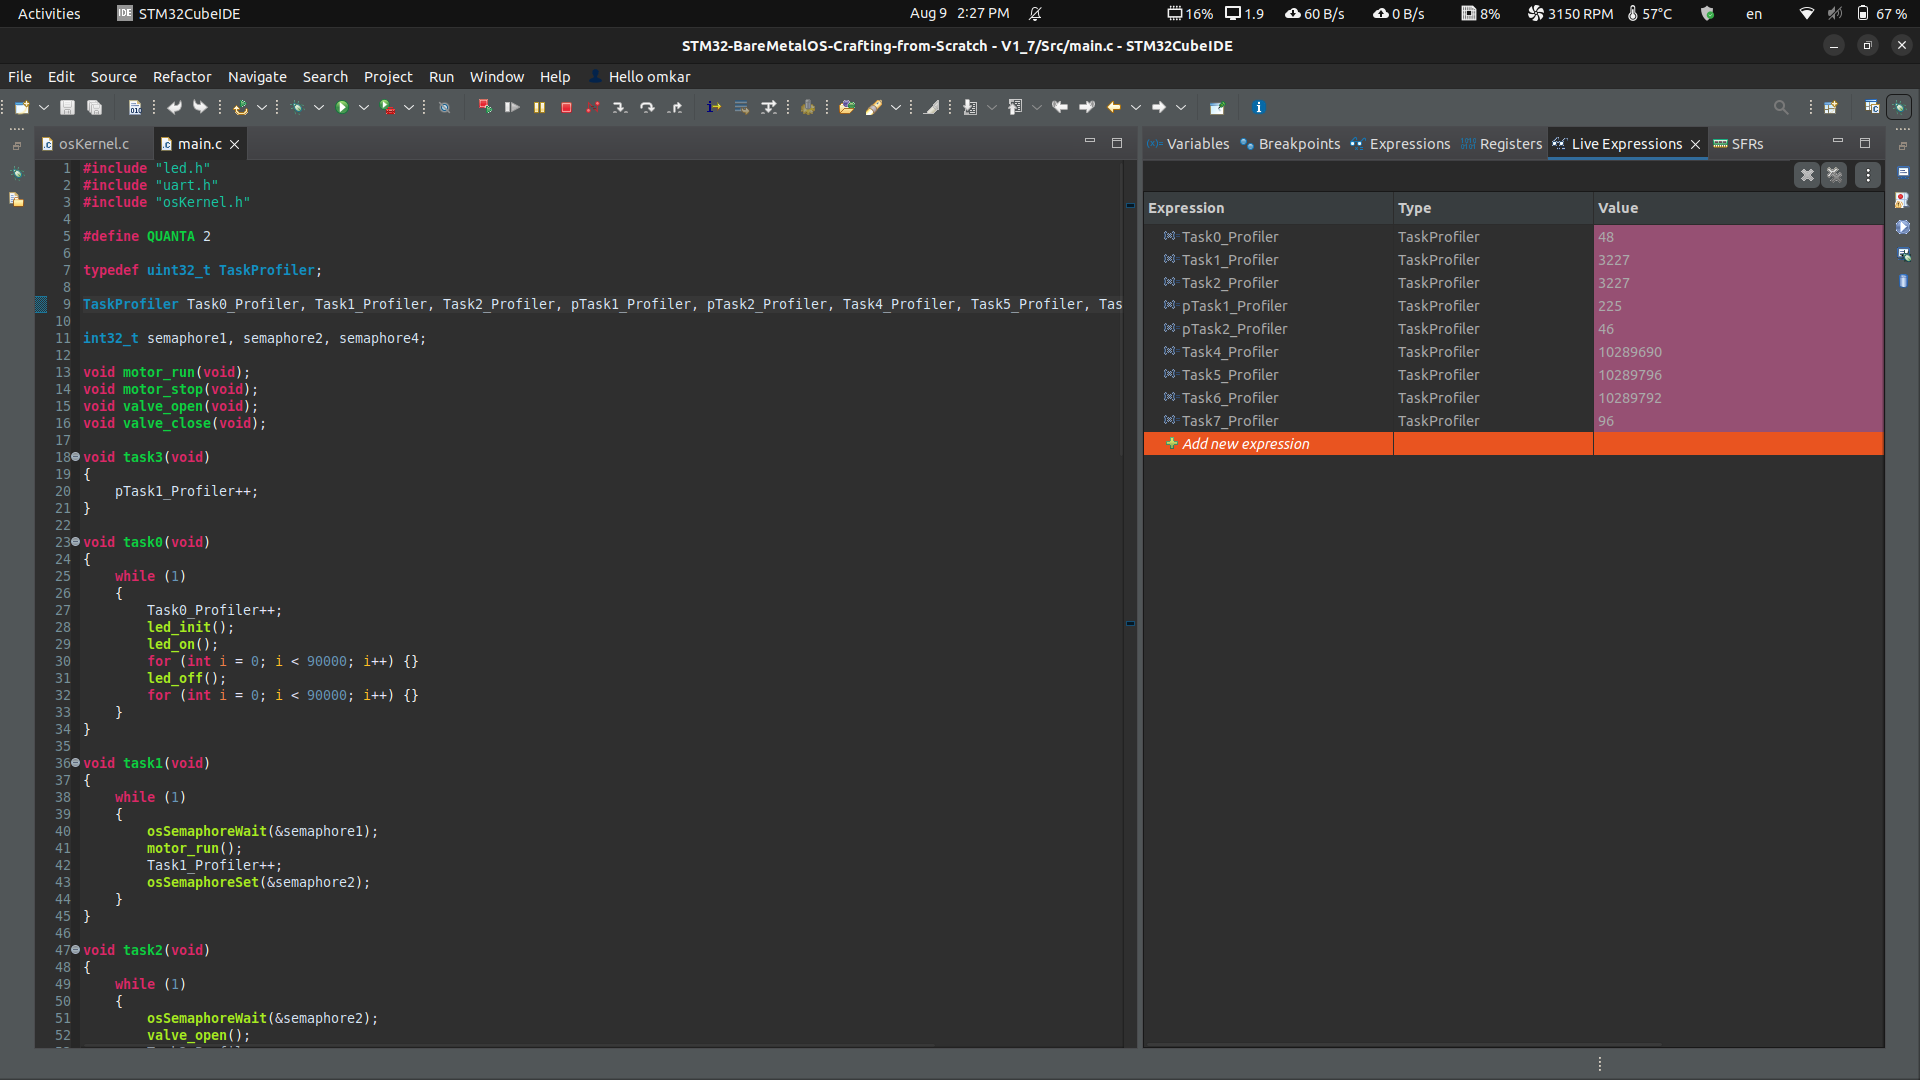
Developed a custom bare-metal operating system for ARM Cortex-M STM32F446xx without using third-party RTOS libraries. Implemented task scheduling, interrupt handling, context switching, and semaphore-like synchronization primitives as part of C-DAC PG-DESD work.

STM32-BareMetalOS-Crafting-from-Scratch
Intelligent_Guided_Vehicle on_BareMetalOS

Designed an autonomous agriculture robot for seeding and crop-cutting workflows. Integrated sensors, actuators, and control logic on STM32 with in-house bare-metal scheduling for deterministic behavior.

Lightweight HTTP Server (Linux System Programming)

Built a minimal HTTP server from scratch in C on Linux using POSIX system calls. Implemented TCP socket communication, request parsing, and static file serving to strengthen core networking and system-programming fundamentals.

Lightweight HTTP Server project preview
OpenGL Real-Time Graphics Projects

Developed multiple modern OpenGL demos with C/C++ covering shaders, VBO/VAO usage, transformations, and texture mapping. Built real-time graphics pipelines and strengthened GPU-side rendering fundamentals.

OpenGL project preview
Linux Device Driver Learning

Hands-on Linux driver and low-level kernel interface practice focused on understanding device interactions, memory handling, and hardware-software integration on Linux systems.

Linux Device Driver project preview